Loading...
Searching...
No Matches
MinModeSaddleSearch Class Reference
#include <MinModeSaddleSearch.h>
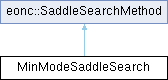
Inheritance diagram for MinModeSaddleSearch:
Public Member Functions | |
| MinModeSaddleSearch (std::shared_ptr< Matter > matterPassed, AtomMatrix modePassed, double reactantEnergyPassed, const Parameters ¶metersPassed, std::shared_ptr< Potential > potPassed) | |
| MinModeSaddleSearch (const MinModeSaddleSearch &)=delete | |
| MinModeSaddleSearch (MinModeSaddleSearch &&) noexcept=default | |
| ~MinModeSaddleSearch ()=default | |
| MinModeSaddleSearch & | operator= (const MinModeSaddleSearch &)=delete |
| MinModeSaddleSearch & | operator= (MinModeSaddleSearch &&) noexcept=default |
| AtomMatrix | getEigenvector () |
| double | getEigenvalue () |
| std::string_view | describeStatus (int status) const override |
| int | getStatus () const override |
| int | getIterationCount () const override |
| int | getForceCalls () const override |
| int | run () override |
| int | run (long max_iterations_override) |
| int | runRetainFrames (long max_iterations_override=-1) |
| Like run(), but also retain climb ConFrames in memory (same stamps as write_movies climb CON). | |
| const std::vector< readcon::ConFrame > & | climbFrames () const |
| void | clearClimbFrames () |
| void | setKnownSaddles (std::vector< AtomMatrix > positions, std::vector< double > energies) |
| Saddles the server already holds for this state (positions, energies). | |
| std::vector< readcon::ConFrame > | takeClimbFrames () |
| Public Member Functions inherited from eonc::SaddleSearchMethod | |
| SaddleSearchMethod (std::shared_ptr< Potential > potPassed, const Parameters ¶msPassed) | |
| virtual | ~SaddleSearchMethod () |
Static Public Member Functions | |
| static constexpr std::string_view | statusMessage (int status) |
| Human-readable message for a status code. | |
| static constexpr int | finalizeClimbStatus (int climbStatus, bool objectiveConverged) noexcept |
| Issue #20 policy: never leave climb as STATUS_GOOD when the climb objective is still unconverged (unfeasible systems must not look like success). | |
Public Attributes | |
| int | forcecalls {0} |
| int | iteration {0} |
| int | status {0} |
Private Member Functions | |
| bool | atKnownSaddle () const |
Private Attributes | |
| std::vector< readcon::ConFrame > | climb_frames_ |
| bool | retain_climb_frames_ {false} |
| AtomMatrix | mode |
| AtomMatrix | initialTangent_ |
| std::shared_ptr< Matter > | matter |
| std::shared_ptr< EigenmodeStrategy > | minModeMethod |
| double | reactantEnergy |
| std::vector< AtomMatrix > | knownSaddlePositions_ |
| std::vector< double > | knownSaddleEnergies_ |
| eonc::log::Scoped | log |
Additional Inherited Members | |
| Protected Attributes inherited from eonc::SaddleSearchMethod | |
| std::shared_ptr< Potential > | pot |
| const Parameters & | params |
Detailed Description
Definition at line 26 of file MinModeSaddleSearch.h.
Member Enumeration Documentation
◆ Status
| enum eonc::MinModeSaddleSearch::Status : int |
Definition at line 29 of file MinModeSaddleSearch.h.
29 : int {
30 // DO NOT CHANGE THE ORDER OF THIS LIST
53 // 22 is ARTnSaddleSearch::STATUS_BAD_ARTN_ERROR
54 STATUS_KNOWN_SADDLE = 23
55 };
@ STATUS_BAD_MAX_CONCAVE_ITERATIONS
Definition MinModeSaddleSearch.h:35
@ STATUS_BAD_HIGH_ENERGY
Definition MinModeSaddleSearch.h:34
@ STATUS_POTENTIAL_FAILED
Definition MinModeSaddleSearch.h:42
@ STATUS_BAD_MAX_ITERATIONS
Definition MinModeSaddleSearch.h:36
@ STATUS_OPTIMIZER_ERROR
Definition MinModeSaddleSearch.h:50
@ STATUS_ZEROMODE_ABORT
Definition MinModeSaddleSearch.h:49
@ STATUS_BAD_NO_BARRIER
Definition MinModeSaddleSearch.h:48
@ STATUS_NEGATIVE_BARRIER
Definition MinModeSaddleSearch.h:45
@ STATUS_BAD_MD_TRAJECTORY_TOO_SHORT
Definition MinModeSaddleSearch.h:46
@ STATUS_NONLOCAL_ABORT
Definition MinModeSaddleSearch.h:44
@ STATUS_DIMER_LOST_MODE
Definition MinModeSaddleSearch.h:51
@ STATUS_NONNEGATIVE_ABORT
Definition MinModeSaddleSearch.h:43
@ STATUS_BAD_NO_NEGATIVE_MODE_AT_SADDLE
Definition MinModeSaddleSearch.h:47
@ STATUS_FAILED_PREFACTOR
Definition MinModeSaddleSearch.h:41
@ STATUS_DIMER_RESTORED_BEST
Definition MinModeSaddleSearch.h:52
@ STATUS_BAD_NOT_CONNECTED
Definition MinModeSaddleSearch.h:37
@ STATUS_BAD_HIGH_BARRIER
Definition MinModeSaddleSearch.h:39
Constructor & Destructor Documentation
◆ MinModeSaddleSearch() [1/3]
| eonc::MinModeSaddleSearch::MinModeSaddleSearch | ( | std::shared_ptr< Matter > | matterPassed, |
| AtomMatrix | modePassed, | ||
| double | reactantEnergyPassed, | ||
| const Parameters & | parametersPassed, | ||
| std::shared_ptr< Potential > | potPassed ) |
Definition at line 318 of file MinModeSaddleSearch.cpp.
323 : SaddleSearchMethod(potPassed, parametersPassed),
324 matter{matterPassed} {
327 reactantEnergy = reactantEnergyPassed;
328 mode = modePassed;
329 initialTangent_ = modePassed;
331 iteration = 0;
332
334
335 // Set reference mode for ImprovedDimer (prevents mode switching)
338 refVec = refVec.array() * matter->getFreeV().array();
339 dimer->setReferenceMode(refVec);
340 }
341}
std::shared_ptr< EigenmodeStrategy > minModeMethod
Definition MinModeSaddleSearch.h:152
SaddleSearchMethod(std::shared_ptr< Potential > potPassed, const Parameters ¶msPassed)
Definition SaddleSearchMethod.h:27
void requireKnownConvergenceMetric(std::string_view metric, std::string_view context)
Throws std::invalid_argument naming context when metric is unrecognized.
Definition HelperFunctions.cpp:372
std::shared_ptr< LowestEigenmode > buildEigenmodeStrategy(std::shared_ptr< Matter > matter, const Parameters ¶ms, std::shared_ptr< Potential > pot)
Definition EigenmodeStrategy.cpp:32
ImprovedDimer * asImprovedDimer(LowestEigenmode &s)
Definition EigenmodeStrategy.h:44
◆ MinModeSaddleSearch() [2/3]
|
delete |
◆ MinModeSaddleSearch() [3/3]
|
defaultnoexcept |
◆ ~MinModeSaddleSearch()
|
default |
Member Function Documentation
◆ atKnownSaddle()
|
nodiscardprivate |
Definition at line 755 of file MinModeSaddleSearch.cpp.
755 {
758 return false;
759 }
764 continue;
765 }
766 Matter known(*matter);
767 known.setPositions(knownSaddlePositions_[k]);
769 return true;
770 }
771 }
772 return false;
773}
std::vector< double > knownSaddleEnergies_
Definition MinModeSaddleSearch.h:155
std::vector< AtomMatrix > knownSaddlePositions_
Definition MinModeSaddleSearch.h:154
double eigenmodeGetEigenvalue(LowestEigenmode &s)
Definition EigenmodeStrategy.h:36
◆ clearClimbFrames()
|
inline |
Definition at line 134 of file MinModeSaddleSearch.h.
134{ climb_frames_.clear(); }
std::vector< readcon::ConFrame > climb_frames_
Definition MinModeSaddleSearch.h:146
◆ climbFrames()
|
inlinenodiscard |
Definition at line 131 of file MinModeSaddleSearch.h.
◆ describeStatus()
|
inlineoverridevirtual |
Implements eonc::SaddleSearchMethod.
Definition at line 114 of file MinModeSaddleSearch.h.
114 {
116 }
static constexpr std::string_view statusMessage(int status)
Human-readable message for a status code.
Definition MinModeSaddleSearch.h:58
◆ finalizeClimbStatus()
|
inlinestaticnodiscardconstexprnoexcept |
Issue #20 policy: never leave climb as STATUS_GOOD when the climb objective is still unconverged (unfeasible systems must not look like success).
Used by run(); unit-tested so deleting this rule fails CI.
Definition at line 95 of file MinModeSaddleSearch.h.
95 {
98 }
99 return climbStatus;
100 }
◆ getEigenvalue()
|
virtual |
Implements eonc::SaddleSearchMethod.
Definition at line 775 of file MinModeSaddleSearch.cpp.
◆ getEigenvector()
|
virtual |
Implements eonc::SaddleSearchMethod.
Definition at line 779 of file MinModeSaddleSearch.cpp.
◆ getForceCalls()
|
inlineoverridevirtual |
◆ getIterationCount()
|
inlineoverridevirtual |
◆ getStatus()
|
inlineoverridevirtual |
◆ operator=() [1/2]
|
delete |
◆ operator=() [2/2]
|
defaultnoexcept |
◆ run() [1/2]
|
overridevirtual |
Implements eonc::SaddleSearchMethod.
Definition at line 343 of file MinModeSaddleSearch.cpp.
343 {
345}
◆ run() [2/2]
| int eonc::MinModeSaddleSearch::run | ( | long | max_iterations_override | ) |
Definition at line 358 of file MinModeSaddleSearch.cpp.
358 {
359 long effectiveMaxIter = max_iterations_override;
360 QUILL_LOG_DEBUG(
362 reactantEnergy);
363
364 int optStatus;
365 bool firstIteration = true;
366 const char *forceLabel =
367 params.optimizer_options().convergence_metric_label.c_str();
368
370 LowestEigenmode::MINMODE_GPRDIMER) {
371 QUILL_LOG_DEBUG(
379 }
383 }
385 params.saddle_search_options().zero_mode_abort_curvature) {
389 }
392 } else {
393
395 LowestEigenmode::MINMODE_DIMER) {
396 QUILL_LOG_INFO(log,
397 "[Dimer] {:9s} {:9s} {:10s} {:18s} {:9s} "
398 "{:7s} {:6s} {:4s} {:5s}\n",
399 "Step", "Step Size", "Delta E", forceLabel, "Curvature",
400 "Torque", "Angle", "Rots", "Align");
402 LowestEigenmode::MINMODE_LANCZOS) {
403 QUILL_LOG_INFO(
404 log,
405 "[Lanczos] {:9s} {:9s} {:10s} {:18s} {:9s} {:10s} {:7s} {:5s}\n",
406 "Step", "Step Size", "Delta E", forceLabel, "Curvature", "Rel Change",
407 "Angle", "Iters");
409 LowestEigenmode::MINMODE_GPRDIMER) {
410 QUILL_LOG_INFO(log,
411 "[GPRDimer] {:9s} {:9s} {:10s} {:18s} {:9s} "
412 " {:7s} {:6s} {:4s}\n",
413 "Step", "Step Size", "Delta E", forceLabel, "Curvature",
414 "Torque", "Angle", "Rots");
415 }
416
417 std::string climbLabel = "climb";
418 std::string climbDatFilename = "climb.dat";
419
421
422 auto objf = std::make_shared<MinModeObjectiveFunction>(
424 auto write_climb_frame = [&](uint64_t frameIndex, bool append,
425 double stepSize, double de, double conv,
426 double eigenval, double torque, double angle,
427 long rotations) {
428 eonc::io::ConFrameMetadata metadata;
429 metadata.frame_index = frameIndex;
440 }
443 matter->matter2con(climbLabel, append, &metadata))) {
445 climbLabel);
446 }
448 matter,
450 }
451
453 std::ofstream climbDat(climbDatFilename,
454 append ? (std::ios::binary | std::ios::app)
455 : std::ios::binary);
456 if (climbDat) {
457 if (!append) {
458 climbDat << "iteration\tstep_size\tdelta_e\tconvergence"
459 "\teigenvalue\ttorque\tangle\trotations\n";
460 }
461 climbDat << std::format("{}\t{:.7e}\t{:.6f}\t{:.5e}\t{:.6f}"
462 "\t{:.6f}\t{:.4f}\t{}\n",
463 frameIndex, stepSize, de, conv, eigenval,
464 torque, angle, rotations);
465 }
466 }
467 };
469 write_climb_frame(0, false, 0.0, 0.0, objf->getConvergence(),
471 0);
472 }
474 objf->getGradient();
480 }
481 }
482
485
486 // Stock max_move stays the cap until a translation crosses max_energy.
487 // A search that never crosses it takes the same steps as before.
489 double translationCap = stockMove;
490 int wallStalls = 0;
491 int wallEvents = 0;
492 int reseeds = 0;
493 int probeForceCalls = 0;
494 auto probedEnergy = [&]() {
496 const double energy = objf->getEnergy();
497 probeForceCalls +=
499 return energy;
500 };
501 auto pullUnderEnergy = [&](const VectorXd &before) -> bool {
503 const VectorXd after = objf->getPositions();
504 const VectorXd delta = objf->difference(after, before);
505 double alpha = 0.5;
506 bool found = false;
507 for (int probe = 0; probe < kMaxEnergyHalvings; ++probe) {
509 kMaxEnergyMotionFloor) {
510 break;
511 }
512 objf->setPositions(before + alpha * delta);
514 found = true;
515 break;
516 }
517 alpha *= 0.5;
518 }
519 auto freshMode = [&]() {
521 if (reseeds % 2 == 1) {
522 seed = -seed;
523 }
524 objf->reseedMode(seed);
525 ++reseeds;
526 };
527 if (found) {
528 wallStalls = 0;
529 ++wallEvents;
531 translationCap =
532 std::min(stockMove, std::max(accepted, kMaxEnergyStepFloor));
533 if (alpha < kMaxEnergyReseedAlpha) {
534 freshMode();
535 QUILL_LOG_DEBUG(
536 log,
537 "[MinMode] energy above max_energy {:.4f}, shortened "
538 "the translation to {:.3e} and re-initialised the mode",
539 limit, accepted);
540 } else {
541 QUILL_LOG_DEBUG(log,
542 "[MinMode] energy above max_energy {:.4f}, shortened "
543 "the translation to {:.3e}",
544 limit, accepted);
545 }
546 if (wallEvents >= kMaxEnergyWallEvents) {
547 QUILL_LOG_DEBUG(log,
548 "[MinMode] {} crossings of max_energy {:.4f}, "
549 "ending the search",
550 wallEvents, limit);
551 return false;
552 }
553 return true;
554 }
555 objf->setPositions(before);
557 return false;
558 }
559 ++wallEvents;
560 ++wallStalls;
561 translationCap = std::min(
562 stockMove, std::max(translationCap * 0.5, kMaxEnergyStepFloor));
563 freshMode();
564 QUILL_LOG_DEBUG(log,
565 "[MinMode] translation stays above max_energy {:.4f}, "
566 "restored the centre and re-initialised the mode",
567 limit);
568 if (wallEvents >= kMaxEnergyWallEvents) {
569 QUILL_LOG_DEBUG(log,
570 "[MinMode] {} crossings of max_energy {:.4f}, "
571 "ending the search",
572 wallEvents, limit);
573 return false;
574 }
575 return wallStalls < kMaxEnergyStalls;
576 };
577
580
581 if (!firstIteration) {
582
585 initialPosition - matter->getPositions(),
586 params.saddle_search_options().nonlocal_distance_abort);
589 break;
590 }
591 }
592
594 params.saddle_search_options().zero_mode_abort_curvature) {
598 break;
599 }
600 }
601 firstIteration = false;
602
605 break;
606 }
607
608 const VectorXd posBefore = objf->getPositions();
610
611 try {
614 params.optimizer_options().method == OptType::CG) {
615 optStatus = optim->step(-translationCap);
616 } else {
617 optStatus = optim->step(translationCap);
618 }
619 } catch (const eonc::DimerModeRestoredException &) {
620 QUILL_LOG_DEBUG(
623 break;
624 } catch (const eonc::DimerModeLostException &) {
627 break;
628 }
629
630 if (optStatus < 0) {
632 break;
633 }
634
637 if (de > energyLimit) {
638 const bool kept = pullUnderEnergy(posBefore);
639 if (kept) {
640 optim->onTranslationPulledBack();
641 }
644 // Count the attempt so a first-step abort does not fall through
645 // to the iteration == 0 mode estimate below.
646 ++iteration;
647 break;
648 }
649 de = objf->getEnergy() - reactantEnergy;
650 } else if (translationCap < stockMove) {
651 translationCap =
652 std::min(stockMove, translationCap * kMaxEnergyCapRegrowth);
653 wallStalls = 0;
654 }
655
656 // Melander, Laasonen, Jonsson, JCTC 11(3), 1055-1062, 2015
659 }
661
662 iteration++;
663
664 // Logging
669 double conv = objf->getConvergence();
670
672 LowestEigenmode::MINMODE_LANCZOS) {
673 QUILL_LOG_DEBUG(
674 log,
675 "[Lanczos] {:9} {:9.6f} {:10.4f} {:18.5e} {:9.4f} {:10.6f} "
676 "{:7.3f} {:5}\n",
677 iteration, stepSize, de, conv, eigenval, torque, angle, rotations);
678 } else {
679 QUILL_LOG_DEBUG(
680 log,
681 "[Dimer] {:9} {:9.7f} {:10.4f} {:18.5e} {:9.4f} {:7.3f} "
682 " {:6.3f} {:4}\n",
683 iteration, stepSize, de, conv, eigenval, torque, angle, rotations);
684 }
685
688 conv, eigenval, torque, angle, rotations);
689 }
690
695 }
698 }
699
703 break;
704 }
705
706 // Check ImprovedDimer mode convergence
708 if (!dimer->rotationDidConverge) {
710 : STATUS_DIMER_LOST_MODE;
713 dimer->getEigenvalue());
714 }
715 break;
716 }
717 }
718 }
719
722 }
723
724 // Never report STATUS_GOOD when the climb objective is unconverged
725 // (issue #20: unfeasible systems must not look like success).
726 const bool climbConverged = objf->isConverged();
731 "refusing STATUS_GOOD");
732 }
733
737 }
740 }
741
743}
Eigen::Matrix< double, Eigen::Dynamic, 3, eOnStorageOrder > AtomMatrix
Definition Eigen.h:37
bool retain_climb_frames_
Definition MinModeSaddleSearch.h:147
static constexpr int finalizeClimbStatus(int climbStatus, bool objectiveConverged) noexcept
Issue #20 policy: never leave climb as STATUS_GOOD when the climb objective is still unconverged (unf...
Definition MinModeSaddleSearch.h:95
long numAtomsMoved(const AtomMatrix v1, double cutoff)
Definition GeometryAnalysis.cpp:302
double maxAtomMotionV(const VectorXd v1)
Definition GeometryAnalysis.cpp:278
void rotationRemove(const AtomMatrix r1, std::shared_ptr< Matter > m2)
Definition GeometryAnalysis.cpp:205
std::unique_ptr< Optimizer > mkOptim(std::shared_ptr< ObjectiveFunction > a_objf, OptType a_otype, const Parameters &a_params)
Definition Optimizer.cpp:55
void saveMode(FILE *modeFile, std::shared_ptr< Matter > matter, AtomMatrix mode)
Write a mode; constrained axes are emitted as 0.
Definition HelperFunctions.cpp:306
readcon::ConFrame matterToConFrame(Matter &m, const ConFrameMetadata *metadata)
Build a single stamped ConFrame from Matter (same builder as matter2con).
Definition ConFileIO.cpp:521
void eigenmodeCompute(LowestEigenmode &s, std::shared_ptr< Matter > matter, AtomMatrix direction)
Definition EigenmodeStrategy.h:31
long eigenmodeTotalForceCalls(LowestEigenmode &s)
Definition EigenmodeStrategy.h:48
long eigenmodeStatsRotations(LowestEigenmode &s)
Definition EigenmodeStrategy.h:56
long eigenmodeTotalIterations(LowestEigenmode &s)
Definition EigenmodeStrategy.h:60
double eigenmodeStatsTorque(LowestEigenmode &s)
Definition EigenmodeStrategy.h:52
double eigenmodeStatsAngle(LowestEigenmode &s)
Definition EigenmodeStrategy.h:54
std::optional< uint64_t > frame_index
Definition ConFileIO.h:72
◆ runRetainFrames()
| int eonc::MinModeSaddleSearch::runRetainFrames | ( | long | max_iterations_override = -1 | ) |
Like run(), but also retain climb ConFrames in memory (same stamps as write_movies climb CON).
Does not require write_movies on disk.
Definition at line 347 of file MinModeSaddleSearch.cpp.
347 {
349 climb_frames_.clear();
350 const long maxIter = max_iterations_override < 0
351 ? params.saddle_search_options().max_iterations
352 : max_iterations_override;
355 return st;
356}
◆ setKnownSaddles()
| void eonc::MinModeSaddleSearch::setKnownSaddles | ( | std::vector< AtomMatrix > | positions, |
| std::vector< double > | energies ) |
Saddles the server already holds for this state (positions, energies).
A climb point with negative curvature that matches one under the structure comparison ends the search with STATUS_KNOWN_SADDLE.
Definition at line 745 of file MinModeSaddleSearch.cpp.
746 {
747 if (positions.size() != energies.size()) {
748 throw std::invalid_argument(
749 "MinModeSaddleSearch::setKnownSaddles: size mismatch");
750 }
751 knownSaddlePositions_ = std::move(positions);
752 knownSaddleEnergies_ = std::move(energies);
753}
◆ statusMessage()
|
inlinestaticconstexpr |
Human-readable message for a status code.
Definition at line 58 of file MinModeSaddleSearch.h.
58 {
59 constexpr std::string_view msgs[] = {
60 "Success", // 0
61 "Initialized", // 1
62 "Initial displacement unable to reach convex region", // 2
63 "Barrier too high", // 3
64 "Too many iterations in concave region", // 4
65 "Too many iterations", // 5
66 "Saddle is not connected to initial state", // 6
67 "Prefactors not within window", // 7
68 "Energy barrier not within window", // 8
69 "Minimizations from saddle did not converge", // 9
70 "Hessian calculation failed", // 10
71 "Potential evaluation failed", // 11
72 "Nonnegative initial mode, aborting", // 12
73 "Nonlocal abort", // 13
74 "Negative barrier detected", // 14
75 "No reaction found during MD trajectory", // 15
76 "Converged to stationary point with zero negative modes", // 16
77 "No forward barrier found along minimized band", // 17
78 "Zero mode abort", // 18
79 "Optimizer error", // 19
80 "Dimer lost mode", // 20
81 "Dimer restored best", // 21
82 };
84 return "Climb reached a known saddle";
88 return "Unknown status";
89 }
◆ takeClimbFrames()
|
inlinenodiscard |
Definition at line 141 of file MinModeSaddleSearch.h.
Member Data Documentation
◆ climb_frames_
|
private |
Definition at line 146 of file MinModeSaddleSearch.h.
◆ forcecalls
Definition at line 127 of file MinModeSaddleSearch.h.
127{0};
◆ initialTangent_
Definition at line 149 of file MinModeSaddleSearch.h.
◆ iteration
Definition at line 128 of file MinModeSaddleSearch.h.
128{0};
◆ knownSaddleEnergies_
|
private |
Definition at line 155 of file MinModeSaddleSearch.h.
◆ knownSaddlePositions_
|
private |
Definition at line 154 of file MinModeSaddleSearch.h.
◆ log
Definition at line 157 of file MinModeSaddleSearch.h.
◆ matter
|
private |
Definition at line 150 of file MinModeSaddleSearch.h.
◆ minModeMethod
|
private |
Definition at line 152 of file MinModeSaddleSearch.h.
◆ mode
Definition at line 148 of file MinModeSaddleSearch.h.
◆ reactantEnergy
|
private |
Definition at line 153 of file MinModeSaddleSearch.h.
◆ retain_climb_frames_
|
private |
Definition at line 147 of file MinModeSaddleSearch.h.
147{false};
◆ status
Definition at line 129 of file MinModeSaddleSearch.h.
129{0};
The documentation for this class was generated from the following files:
- /home/runner/work/eOn/eOn/include/eon/MinModeSaddleSearch.h
- /home/runner/work/eOn/eOn/client/MinModeSaddleSearch.cpp
- Generated by
 1.17.0