Loading...
Searching...
No Matches
NEBObjectiveFunction Class Reference
#include <NudgedElasticBand.h>
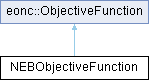
Inheritance diagram for NEBObjectiveFunction:
Public Member Functions | |
| NEBObjectiveFunction (NudgedElasticBand *nebPassed, const Parameters ¶metersPassed) | |
| ~NEBObjectiveFunction (void) | |
| VectorXd | getGradient (bool fdstep=false) |
| double | getEnergy () |
| void | setPositions (const VectorXd &x) |
| VectorXd | getPositions () |
| int | degreesOfFreedom () |
| bool | isConverged () |
| bool | isUncertain () |
| double | getConvergence () |
| VectorXd | difference (const VectorXd &a, const VectorXd &b) |
| VectorXd | getMasses () const override |
| bool | supportsFiniteDifferenceCurvature () const override |
| bool | gradientMatchesEnergy () const override |
| bool | reuseDisplacementCurvature () const override |
| Public Member Functions inherited from eonc::ObjectiveFunction | |
| ObjectiveFunction (const Parameters ¶msPassed) | |
| virtual | ~ObjectiveFunction () |
| virtual bool | pastClimbCeiling () |
| virtual std::optional< double > | knownCurvature () const |
| virtual void | minimumImage (Eigen::Ref< Eigen::Vector3d >) const |
| virtual bool | getPeriodic () const |
Public Attributes | |
| NudgedElasticBand::NEBStatus | status |
Private Attributes | |
| NudgedElasticBand * | neb |
Additional Inherited Members | |
| Protected Attributes inherited from eonc::ObjectiveFunction | |
| const Parameters & | params |
Detailed Description
Definition at line 146 of file NudgedElasticBand.h.
Constructor & Destructor Documentation
◆ NEBObjectiveFunction()
|
inline |
Definition at line 148 of file NudgedElasticBand.h.
ObjectiveFunction(const Parameters ¶msPassed)
Definition ObjectiveFunction.h:25
◆ ~NEBObjectiveFunction()
|
inline |
Definition at line 153 of file NudgedElasticBand.h.
153{};
Member Function Documentation
◆ degreesOfFreedom()
|
virtual |
Implements eonc::ObjectiveFunction.
Definition at line 93 of file NEBObjectiveFunction.cpp.
◆ difference()
|
virtual |
Implements eonc::ObjectiveFunction.
Definition at line 148 of file NEBObjectiveFunction.cpp.
149 {
152 VectorXd pbcDiff(seg * neb->numImages);
154 const int n = (i - 1) * static_cast<int>(seg);
155 pbcDiff.segment(n, atomDof) =
156 neb->path[i]->pbcV(a.segment(n, atomDof) - b.segment(n, atomDof));
158 pbcDiff.segment(n + atomDof, 9) =
159 a.segment(n + atomDof, 9) - b.segment(n + atomDof, 9);
160 }
161 }
162 return pbcDiff;
163}
◆ getConvergence()
|
virtual |
Implements eonc::ObjectiveFunction.
Definition at line 118 of file NEBObjectiveFunction.cpp.
◆ getEnergy()
|
virtual |
Implements eonc::ObjectiveFunction.
Definition at line 47 of file NEBObjectiveFunction.cpp.
◆ getGradient()
|
virtual |
Implements eonc::ObjectiveFunction.
Definition at line 24 of file NEBObjectiveFunction.cpp.
24 {
26 neb->updateForces();
29 VectorXd gradV(seg * neb->numImages);
31 // Negate in-place during copy to avoid a second pass over 40KB
32 gradV.segment(seg * (i - 1), atomDof) =
33 -VectorXd::Map(neb->projectedForce[i]->data(), atomDof);
37 neb->solidJacobian());
38 gradV.segment(seg * (i - 1), atomDof) =
39 -VectorXd::Map(step.positions.data(), atomDof);
40 gradV.segment(seg * (i - 1) + atomDof, 9) =
41 -VectorXd::Map(step.cell.data(), 9);
42 }
43 }
44 return gradV;
45}
CartesianStep solidStateCartesianStep(const Matter &image, const AtomMatrix &atomicForce, const Matrix3d &cellForce, double jacobian)
Definition SolidStateNEB.cpp:231
◆ getMasses()
|
overridevirtual |
Reimplemented from eonc::ObjectiveFunction.
Definition at line 122 of file NEBObjectiveFunction.cpp.
122 {
123 long count = 0;
128 if (mask.row(atom).sum() > 0.5) {
129 ++count;
130 }
131 }
132 }
133 VectorXd masses(count);
134 long written = 0;
140 if (mask.row(atom).sum() > 0.5) {
141 masses(written++) = all(atom);
142 }
143 }
144 }
145 return masses;
146}
Eigen::Matrix< double, Eigen::Dynamic, 3, eOnStorageOrder > AtomMatrix
Definition Eigen.h:37
Eigen::Matrix< double, Eigen::Dynamic, 1 > getMasses() const
Definition Matter.cpp:843
◆ getPositions()
|
virtual |
Implements eonc::ObjectiveFunction.
Definition at line 77 of file NEBObjectiveFunction.cpp.
77 {
80 VectorXd posV(seg * neb->numImages);
82 const long offset = seg * (i - 1);
83 posV.segment(offset, atomDof) =
84 VectorXd::Map(neb->path[i]->getPositions().data(), atomDof);
86 posV.segment(offset + atomDof, 9) =
87 VectorXd::Map(neb->path[i]->getCell().data(), 9);
88 }
89 }
90 return posV;
91}
◆ gradientMatchesEnergy()
|
inlineoverridevirtual |
Reimplemented from eonc::ObjectiveFunction.
Definition at line 170 of file NudgedElasticBand.h.
170{ return false; }
◆ isConverged()
|
virtual |
Implements eonc::ObjectiveFunction.
Definition at line 113 of file NEBObjectiveFunction.cpp.
113 {
115 return force_conv;
116}
◆ isUncertain()
Definition at line 97 of file NEBObjectiveFunction.cpp.
97 {
98 double maxMaxUnc = std::numeric_limits<double>::lowest();
99 double currentMaxUnc{0};
101 currentMaxUnc = neb->path[idx]->getEnergyVariance();
102 if (currentMaxUnc > maxMaxUnc) {
103 maxMaxUnc = currentMaxUnc;
104 }
105 }
107 if (unc_conv) {
108 this->status = NudgedElasticBand::NEBStatus::MAX_UNCERTAINTY;
109 }
110 return unc_conv;
111}
◆ reuseDisplacementCurvature()
|
inlineoverridevirtual |
Reimplemented from eonc::ObjectiveFunction.
Definition at line 171 of file NudgedElasticBand.h.
171{ return true; }
◆ setPositions()
|
virtual |
Implements eonc::ObjectiveFunction.
Definition at line 59 of file NEBObjectiveFunction.cpp.
59 {
64 const long offset = seg * (i - 1);
66 Matrix3d cell = Matrix3d::Map(x.segment(offset + atomDof, 9).data());
67 cell(0, 1) = 0.0;
68 cell(0, 2) = 0.0;
69 cell(1, 2) = 0.0;
70 neb->path[i]->setCell(cell);
71 }
72 neb->path[i]->setPositions(
73 AtomMatrix::Map(x.segment(offset, atomDof).data(), neb->atoms, 3));
74 }
75}
◆ supportsFiniteDifferenceCurvature()
|
inlineoverridevirtual |
Reimplemented from eonc::ObjectiveFunction.
Definition at line 167 of file NudgedElasticBand.h.
167{ return false; }
Member Data Documentation
◆ neb
Definition at line 175 of file NudgedElasticBand.h.
◆ status
Definition at line 172 of file NudgedElasticBand.h.
The documentation for this class was generated from the following files:
- /home/runner/work/eOn/eOn/include/eon/NudgedElasticBand.h
- /home/runner/work/eOn/eOn/client/NEBObjectiveFunction.cpp
- Generated by
 1.17.0